RESEARCH · UIUC ADVANCED CONTROLS RESEARCH LAB
Glove Control
A wireless IMU glove for safer, more portable drone teleoperation
Glove hardware and ROS pipeline, with Ansh Tulsyan
- ESP32 → ROS → PX4
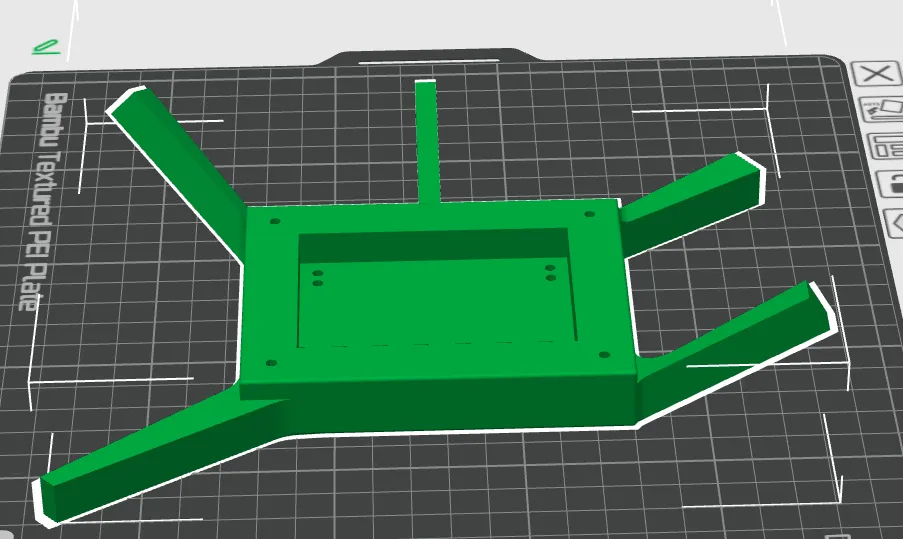
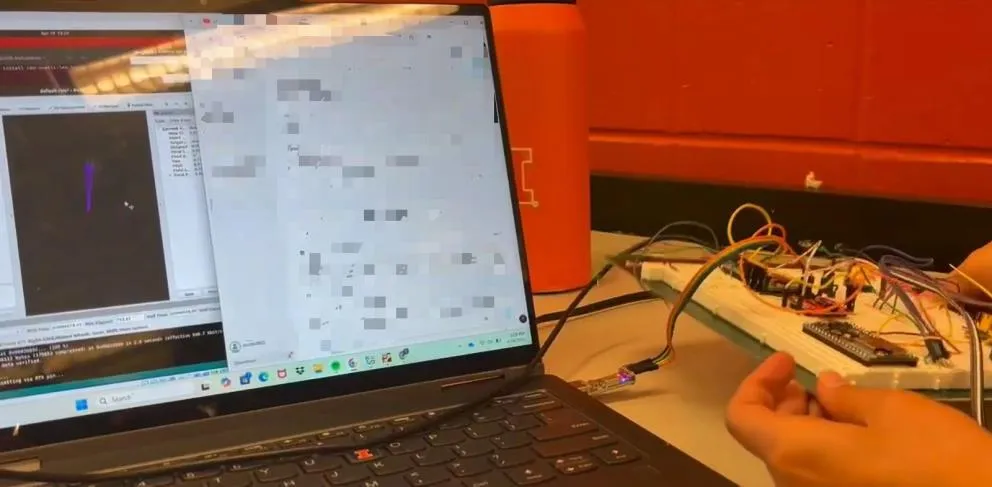
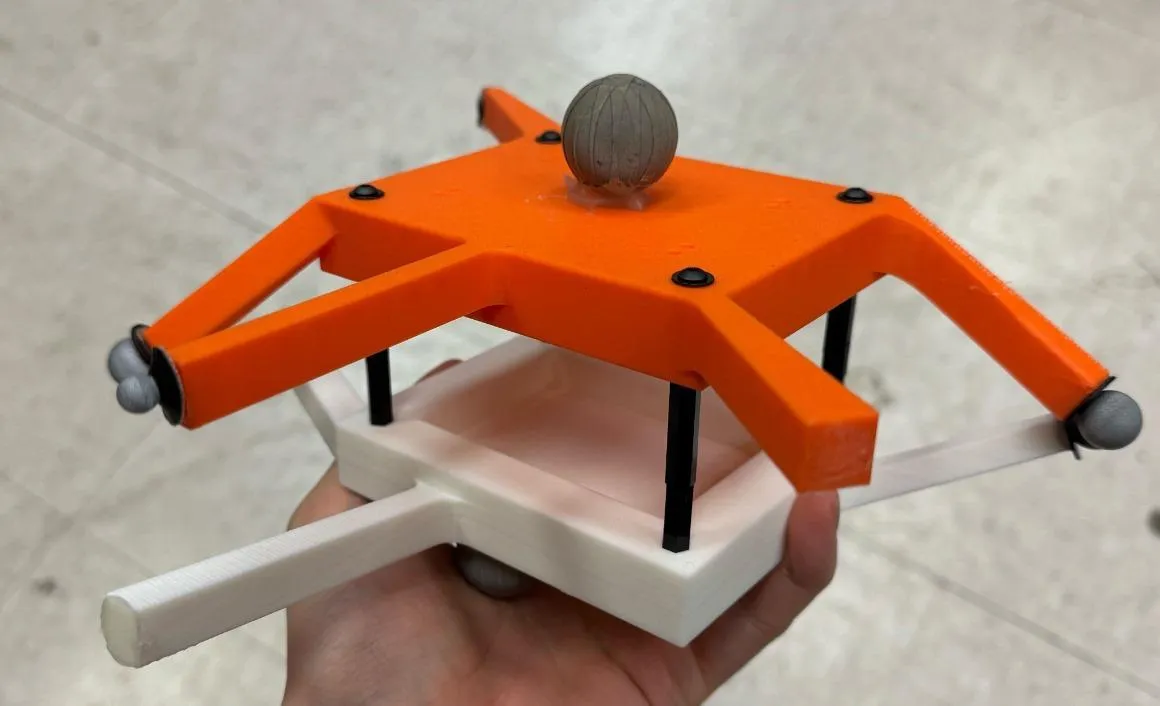
The first version tracked a 3D-printed glove with Vicon markers, which meant the operator had to stand inside the flight volume. The redesign puts a 9-DOF IMU and an ESP32 on a rigid PLA glove and streams pose wirelessly to a ground station, where ROS filters it with a Kalman filter and MAVROS turns it into PX4 commands. Buttons on the glove trigger discrete actions, like a servo-driven payload gripper on the drone.