RESEARCH · UIUC AUGMENTED LISTENING LAB
Spider-Bot
A room-sized parallel-cable robot for artefact-free acoustic data collection
Mechanical design lead
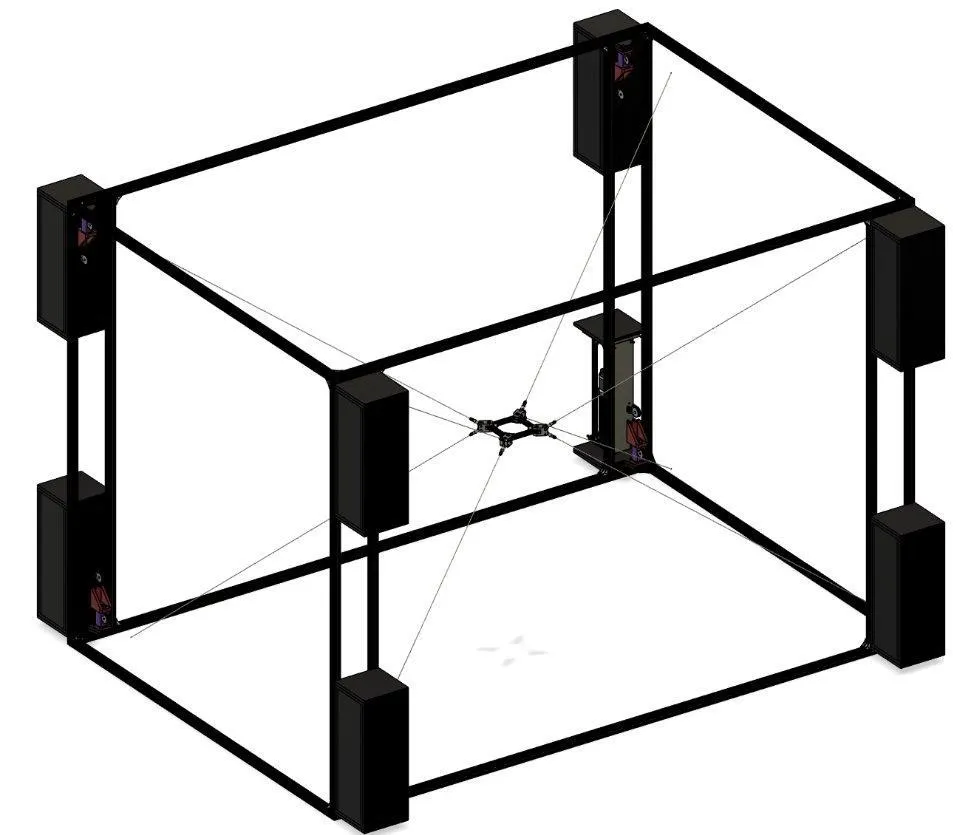
- 8 winch modules
- ~30% less perceived noise
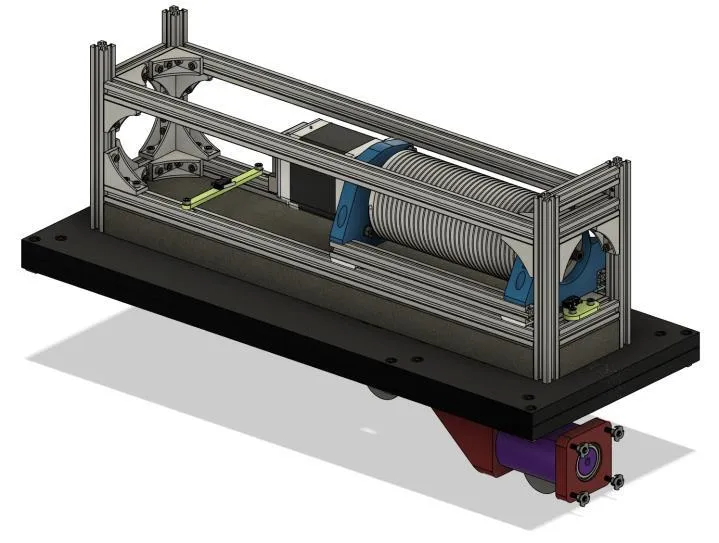
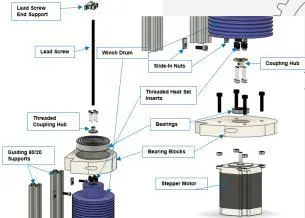
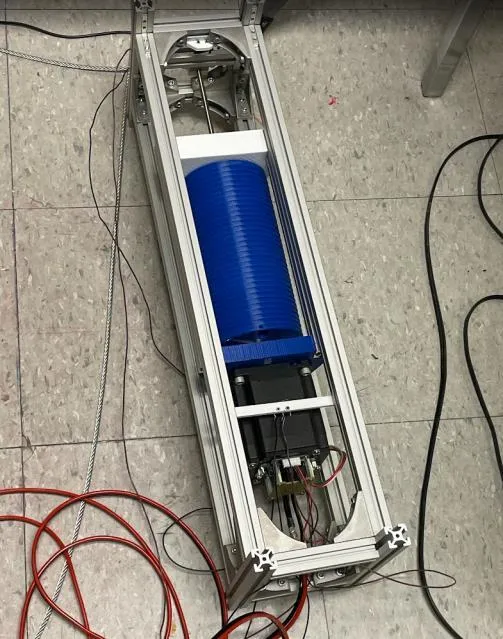
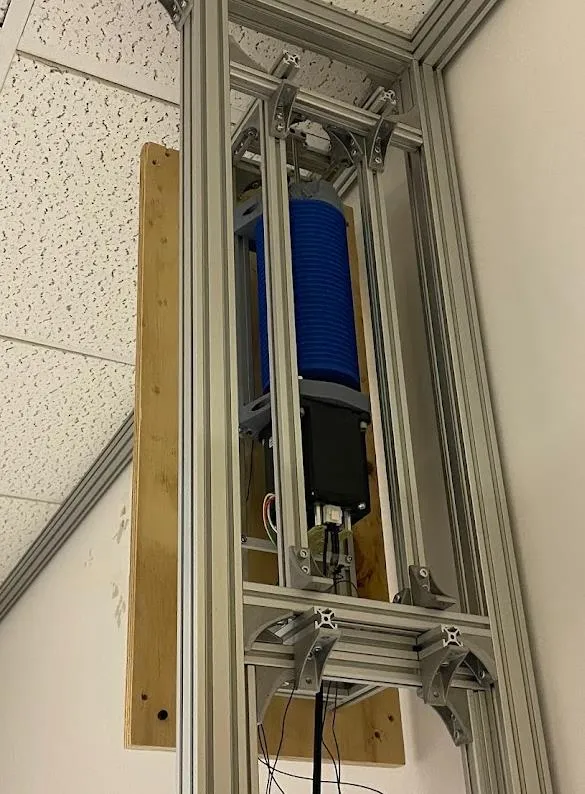
Eight winch modules, four on the ceiling and four on the floor, set steel-cable lengths from an inverse-kinematics solve to move a microphone array anywhere in the room, without the motion artefacts of a hand-held boom pole. In each winch, an internally threaded, grooved spool travels along a lead screw as it winds, so the motor axis stays fixed and backlash and radial vibration stay low. With silent stepper drivers and vibration-damped mounts, this replaced the lab’s earlier direct-pulley design and cut perceived room noise by about 30% (~10 dB).